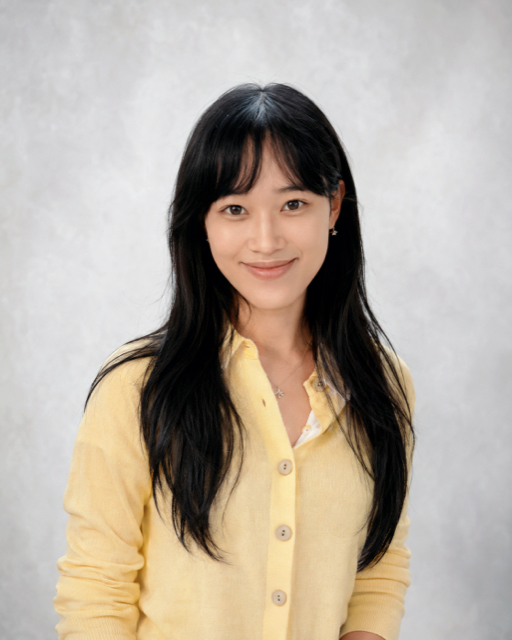
I am a Ph.D. student in Computer Science at the University of California, Los Angeles, advised by Professors Chenfanfu Jiang, Demetri Terzopoulos, and Bolei Zhou. My research focuses on world models, vision-language-action models, and scalable robot-learning systems.
I received my B.Sc. in Mathematics with Statistics for Finance from Imperial College London. Before UCLA, I was a machine learning researcher at AgiBot, where I worked on EnerVerse-AC, AgiBot World Colosseo, Genie Envisioner, and large-scale embodied AI training systems. I also collaborated with Nirvana Robotics on memory-augmented world models and agentic policy generation.
Email | Gmail | Google Scholar
I am always open to collaborations on scalable robot data, robot world models, vision-language-action systems, and embodied AI. I also believe commercializing robotics ideas is important, and I welcome conversations with entrepreneurs and builders. Please drop me an email.
Research Interest
My primary research interest is scalable robot data: building pipelines that turn diverse data sources into action-grounded experience for robot foundation models. I study how robots can learn from simulation, human videos, real robot trajectories, synthetic generation, automated annotation, and data filtering to acquire generalizable manipulation skills.
- Scalable Robot Data: How can heterogeneous sources be converted into reusable, action-grounded training data for robot foundation models?
- Data Pipelines: How can simulation, synthetic generation, video-to-action conversion, and automated filtering scale robot learning reliably?
- World Models: How can robots use memory and predictive video models to reason over long-horizon manipulation?
- Vision-Language-Action Models: How can multimodal foundation models generate actions that transfer across tasks and embodiments?
Publications
Yellow background indicates selected papers. * indicates equal contribution.
Genie Envisioner: A Unified World Foundation Platform for Robotic Manipulation
Yue Liao, Pengfei Zhou, Siyuan Huang, Donglin Yang, Shengcong Chen, Yuxin Jiang, Yue Hu, Si Liu, Jianlan Luo, Liliang Chen, Shuicheng Yan, Maoqing Yao, Guanghui Ren
International Conference on Learning Representations (ICLR), 2026
AgiBot World Colosseo: A Large-Scale Manipulation Platform for Scalable and Intelligent Embodied Systems
Qingwen Bu, Guanghui Ren, Chiming Liu, Modi Shi, ..., Yuxin Jiang, ..., Hongyang Li, Yu Qiao, Maoqing Yao (AgiBot World Team)
IEEE Transactions on Robotics, 2026
IROS 2025 Best Paper Finalist
Genie Centurion: Accelerating Scalable Real-World Robot Training with Human Rewind-and-Refine Guidance
Wenhao Wang, Jianheng Song, Chiming Liu, Jiayao Ma, Siyuan Feng, Jingyuan Wang, Yuxin Jiang, Kylin Chen, Sikang Zhan, Yi Wang, Tong Meng, Modi Shi, Xindong He, Guanghui Ren, Yang Yang, Maoqing Yao
arXiv preprint, 2025
EnerVerse-AC: Envisioning Embodied Environments with Action Condition
Yuxin Jiang*, Shengcong Chen*, Siyuan Huang*, Liliang Chen, Pengfei Zhou, Yue Liao, Xindong He, Chiming Liu, Hongsheng Li, Maoqing Yao, Guanghui Ren
NeurIPS 2025 Workshop on Embodied World Models for Decision Making. Oral presentation and Outstanding Paper Award.
Official baseline model for the world-model track of the AgiBot World Challenge at ICRA 2026.
Experience
- University of California, Los Angeles, Ph.D. Student in Computer Science, 2026.09-present.
- Nirvana Robotics, Research Collaborator, 2026.01-2026.09.
- UCLA AI & Visual Computing Laboratory, Visiting Researcher, 2025.09-2026.07.
- AgiBot AI Research Institute, Machine Learning Researcher, 2024.06-2025.08.
- Ant Group AI Digital Human Institute, ML Engineer and Technical PM Intern, 2024.01-2024.05.
- Imperial College London, B.Sc. in Mathematics with Statistics for Finance, 2020.10-2023.08.
Personal
In recent years, I have enjoyed reading Carl Jung, Hermann Hesse, and Jiddu Krishnamurti. I am happy to chat about psychology, literature, philosophy, and the ways these ideas shape how we think about intelligence, agency, and human experience.